INDOOR FARMS & PACKHOUSES
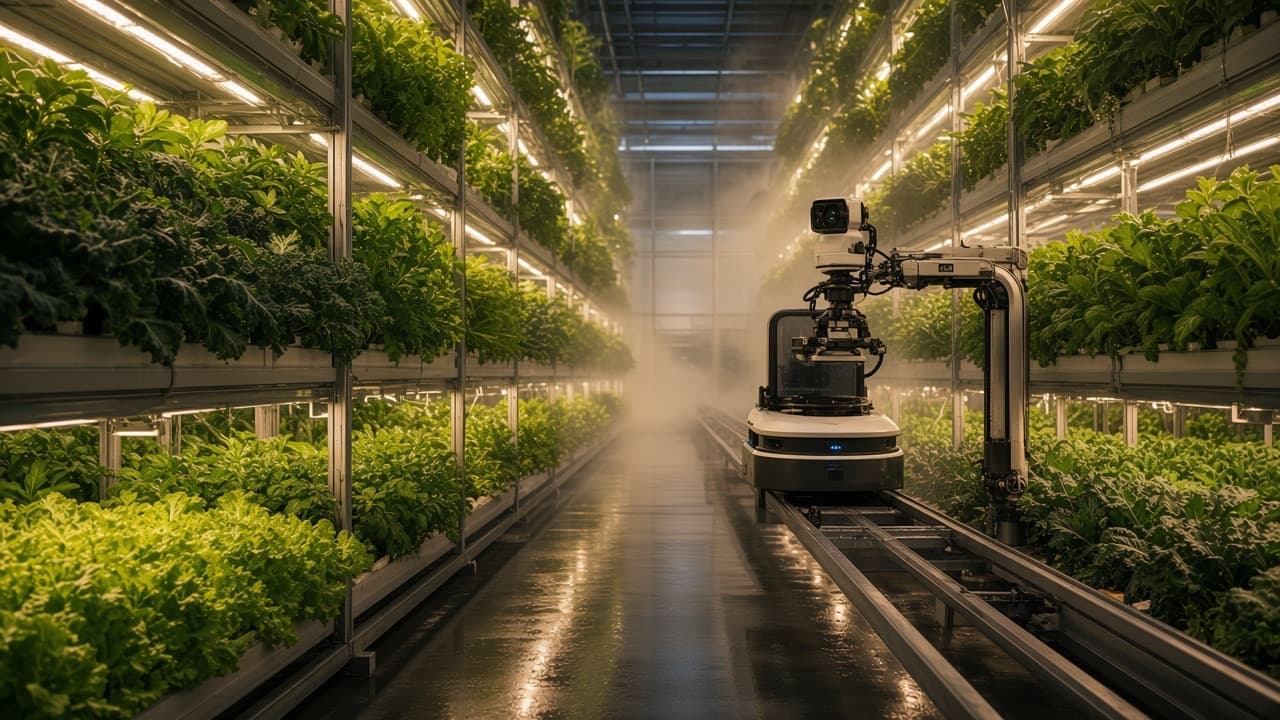
Harvest and scouting robots served from the farm's pool over the farm's own network, with the crop models staying the grower's.
THE PROBLEM
Where the work is.
An indoor farm is a floor of plants that look like no other grower's plants. Harvest and scouting robots arrive with models trained on a general crop and improve only if the grower's imagery leaves the farm. A pool on the farm tunes the models overnight on the grower's own rows, and serves them to every robot the next day.
FACILITIES · CZAR GRID
CONSTRAINTS
Why a GPU on every machine fails here.
A general crop model does not see this grower's crop.
Imagery of the rows is the grower's competitive material.
A robot in a warm, humid house should carry as little compute as possible.
Each robot vendor's cloud is a separate path out of the farm.
DEPLOYMENT
How the Grid deploys.
- 01
Place the pool
Czar nodes in the building's own rack, on the building's own network.
- 02
Connect the fleet
Each vendor's software calls the pool. Safety and motion stay on the machine.
- 03
Run the site's tasks
Authored, approved, and recorded in Agency Studio on the Grid.
REPRESENTATIVE USE CASES
What a site runs on it.
Illustrative capabilities, not accounts of specific deployments.
Harvest robots from the rack
Harvest and scouting robots served from the farm's pool over the farm's own network; the crop models stay the grower's.
A greenhouse that learns itself
Models tune overnight on the farm's own imagery, on the pool, so the next day's robots see this grower's crop.
Reading and boundary
READING
A greenhouse whose crop models stay the grower's
Harvest and scouting robots arrive at an indoor farm with models trained on a general crop, and improve only if the grower's imagery leaves. A Czar Grid on the farm tunes the models overnight on the grower's own rows and serves them to every robot the next day.
Safety, stops and motion stay on the machine as its vendor built them. Czar Grid serves perception, decisions and adaptation over the site's network; it is not a controller and does not sit inside any real-time or safety loop.